Loop noise bandwidth

Derivations of 3-dB and Loop Noise Bandwidths

Loop bandwidth is the most important parameter in a Phase Locked Loop (PLL) for phase synchronization and PLL for timing recovery. Today we will cover its significance and derive the relevant expressions. Loop Bandwidth Loop bandwidth is the frequency range over which a PLL can effectively track variations in the phase and frequency of its input reference signal. It not only serves as the primary filtering metric for the system but also determines how quickly the PLL can lock into convergence. As with most other technical concepts, the loop bandwidth presents a critical design trade-off: the smaller the loop bandwidth,

Continue reading
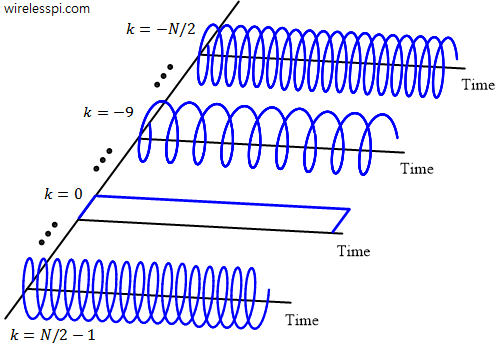
Complex sinusoids drawn to highlight the discrete frequency axis k on the left side

Discrete Frequency

An Analog to Digital Converter (ADC) samples a continuous-time signal to produce discrete-time samples. For a digital signal processor, this signal just resides in memory as a sequence of numbers. Consequently, the knowledge of the sample rate $F_S$ is the key to signal manipulation in digital domain. As far as time is concerned, one can easily determine the period or frequency of such a signal stored in the memory. For example, the period $T$ in the sinusoid of Figure below is clearly $10$ samples and sample time $T_S=1/F_S$ can be employed to find its period in seconds. For a sample

Continue reading
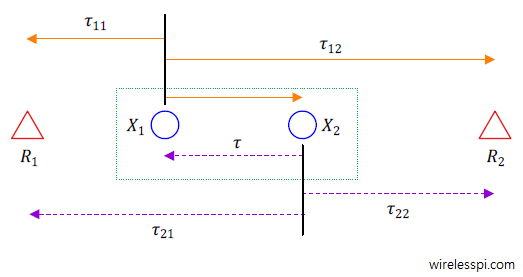
Setup for Differential Phase Difference of Arrival (DPDoA)

Location Estimation through Differential Phase Difference of Arrival

In an article on carrier phase based ranging, we saw how phase observations were employed to find the range between two wireless devices. Today we explore how phase can also be used for the purpose of location estimation. Background To determine the position of a wireless device, its range needs to be computed from a set of anchor nodes. When these anchors and the device itself are synchronized with each other, the signal propagation time of an electromagnetic wave arriving at these anchors after its emission from a Tx can be employed to calculate the corresponding distances. This is the

Continue reading
Magnitude of frequency response |H[k]| in response to complex sinusoids at all N frequencies

System Characterization

In wireless communications and other applications of digital signal processing, we often want to modify a generated or acquired signal. A device or algorithm that performs some prescribed operations on an input signal to generate an output signal is called a system. In another article about transforming a signal, we saw how a signal can be scaled and time shifted, or added and multiplied with another signal. These are all examples of a system. Amplifiers in communication receivers and filters in image processing applications are some systems that we interact with in daily lives. A communication channel is also a

Continue reading
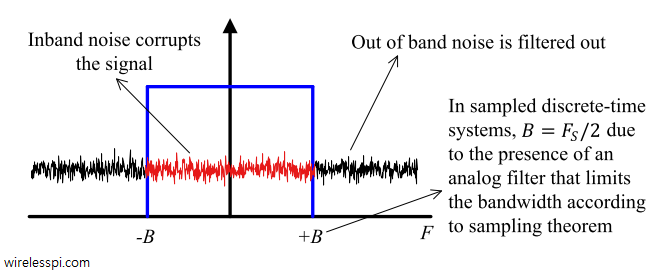
Computing noise power within a specified bandwidth

Additive White Gaussian Noise (AWGN)

The performance of a digital communication system is quantified by the probability of bit detection errors in the presence of thermal noise. In the context of wireless communications, the main source of thermal noise is addition of random signals arising from the vibration of atoms in the receiver electronics. You can also watch the video below. The term additive white Gaussian noise (AWGN) originates due to the following reasons: [Additive] The noise is additive, i.e., the received signal is equal to the transmitted signal plus noise. This gives the most widely used equality in communication systems. \begin{equation}\label{eqIntroductionAWGNadditive} r(t) = s(t)

Continue reading